RoutePilot Pro
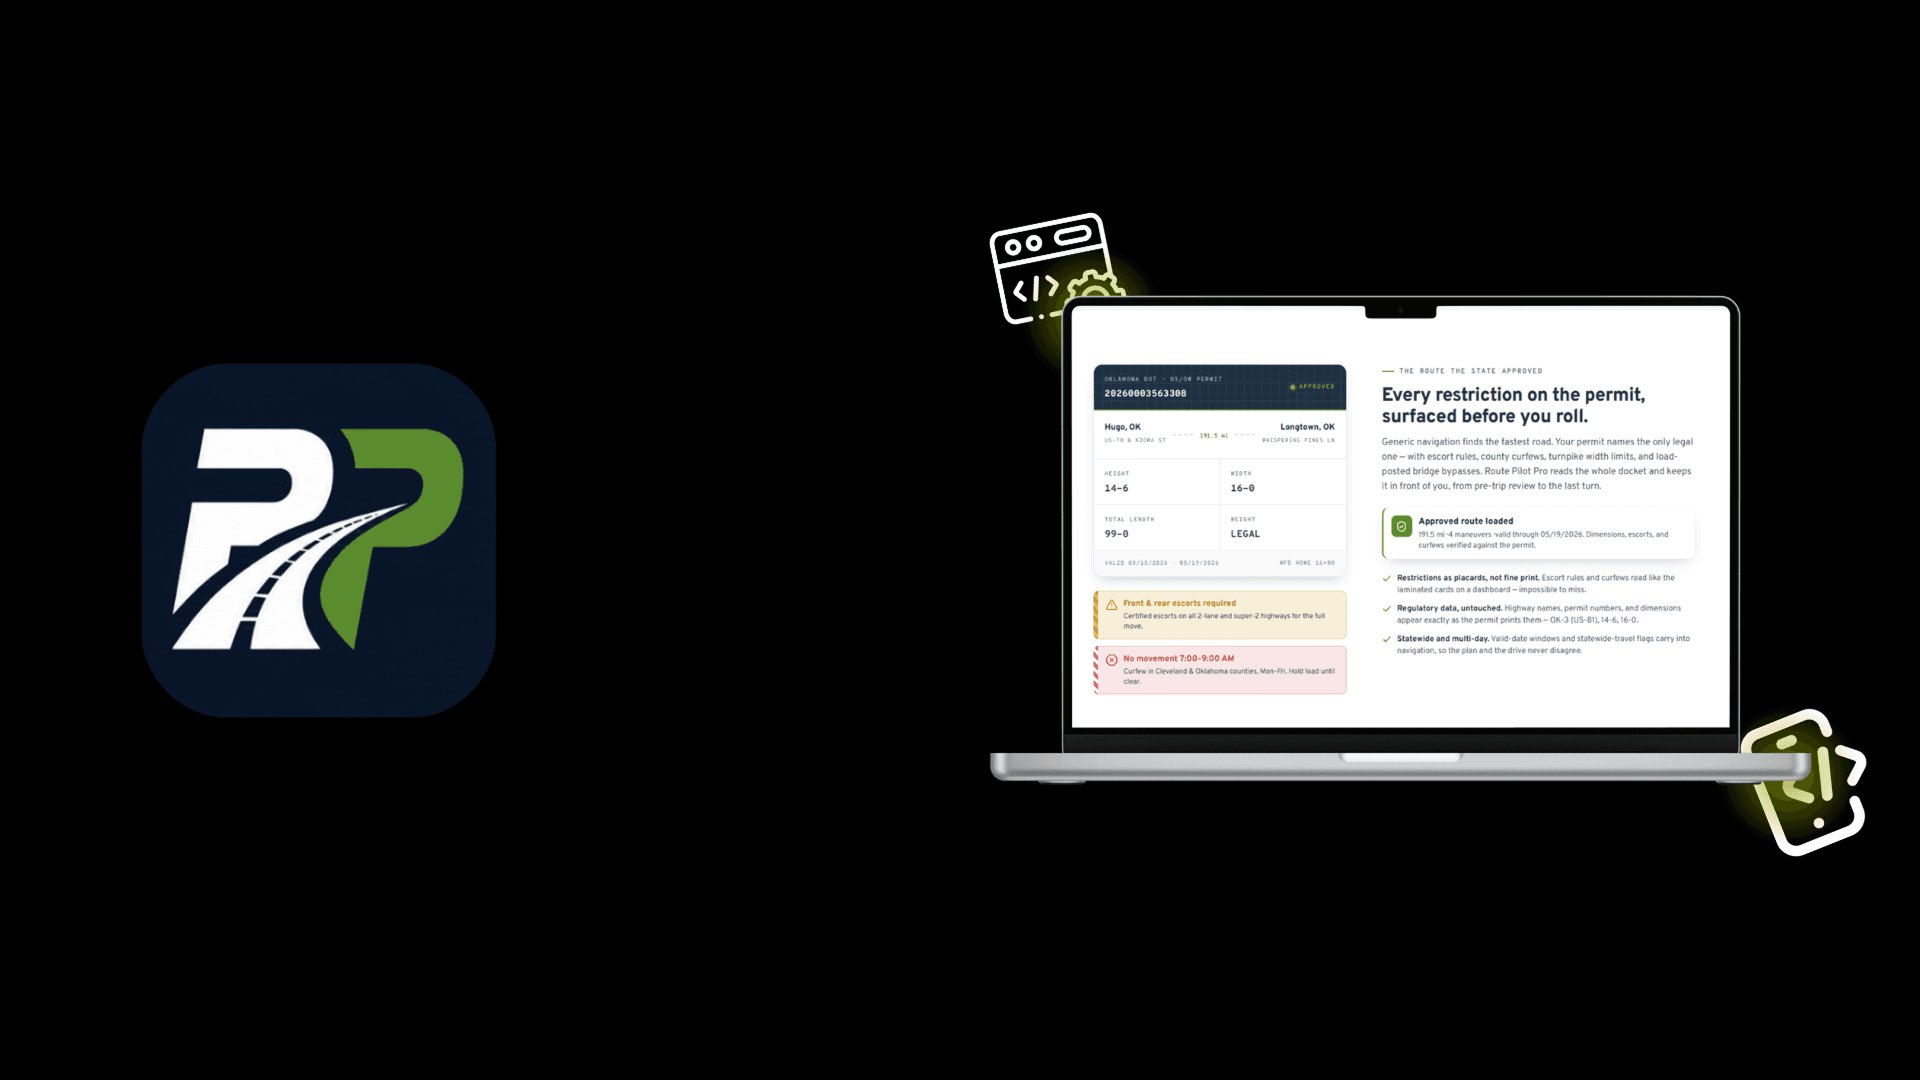
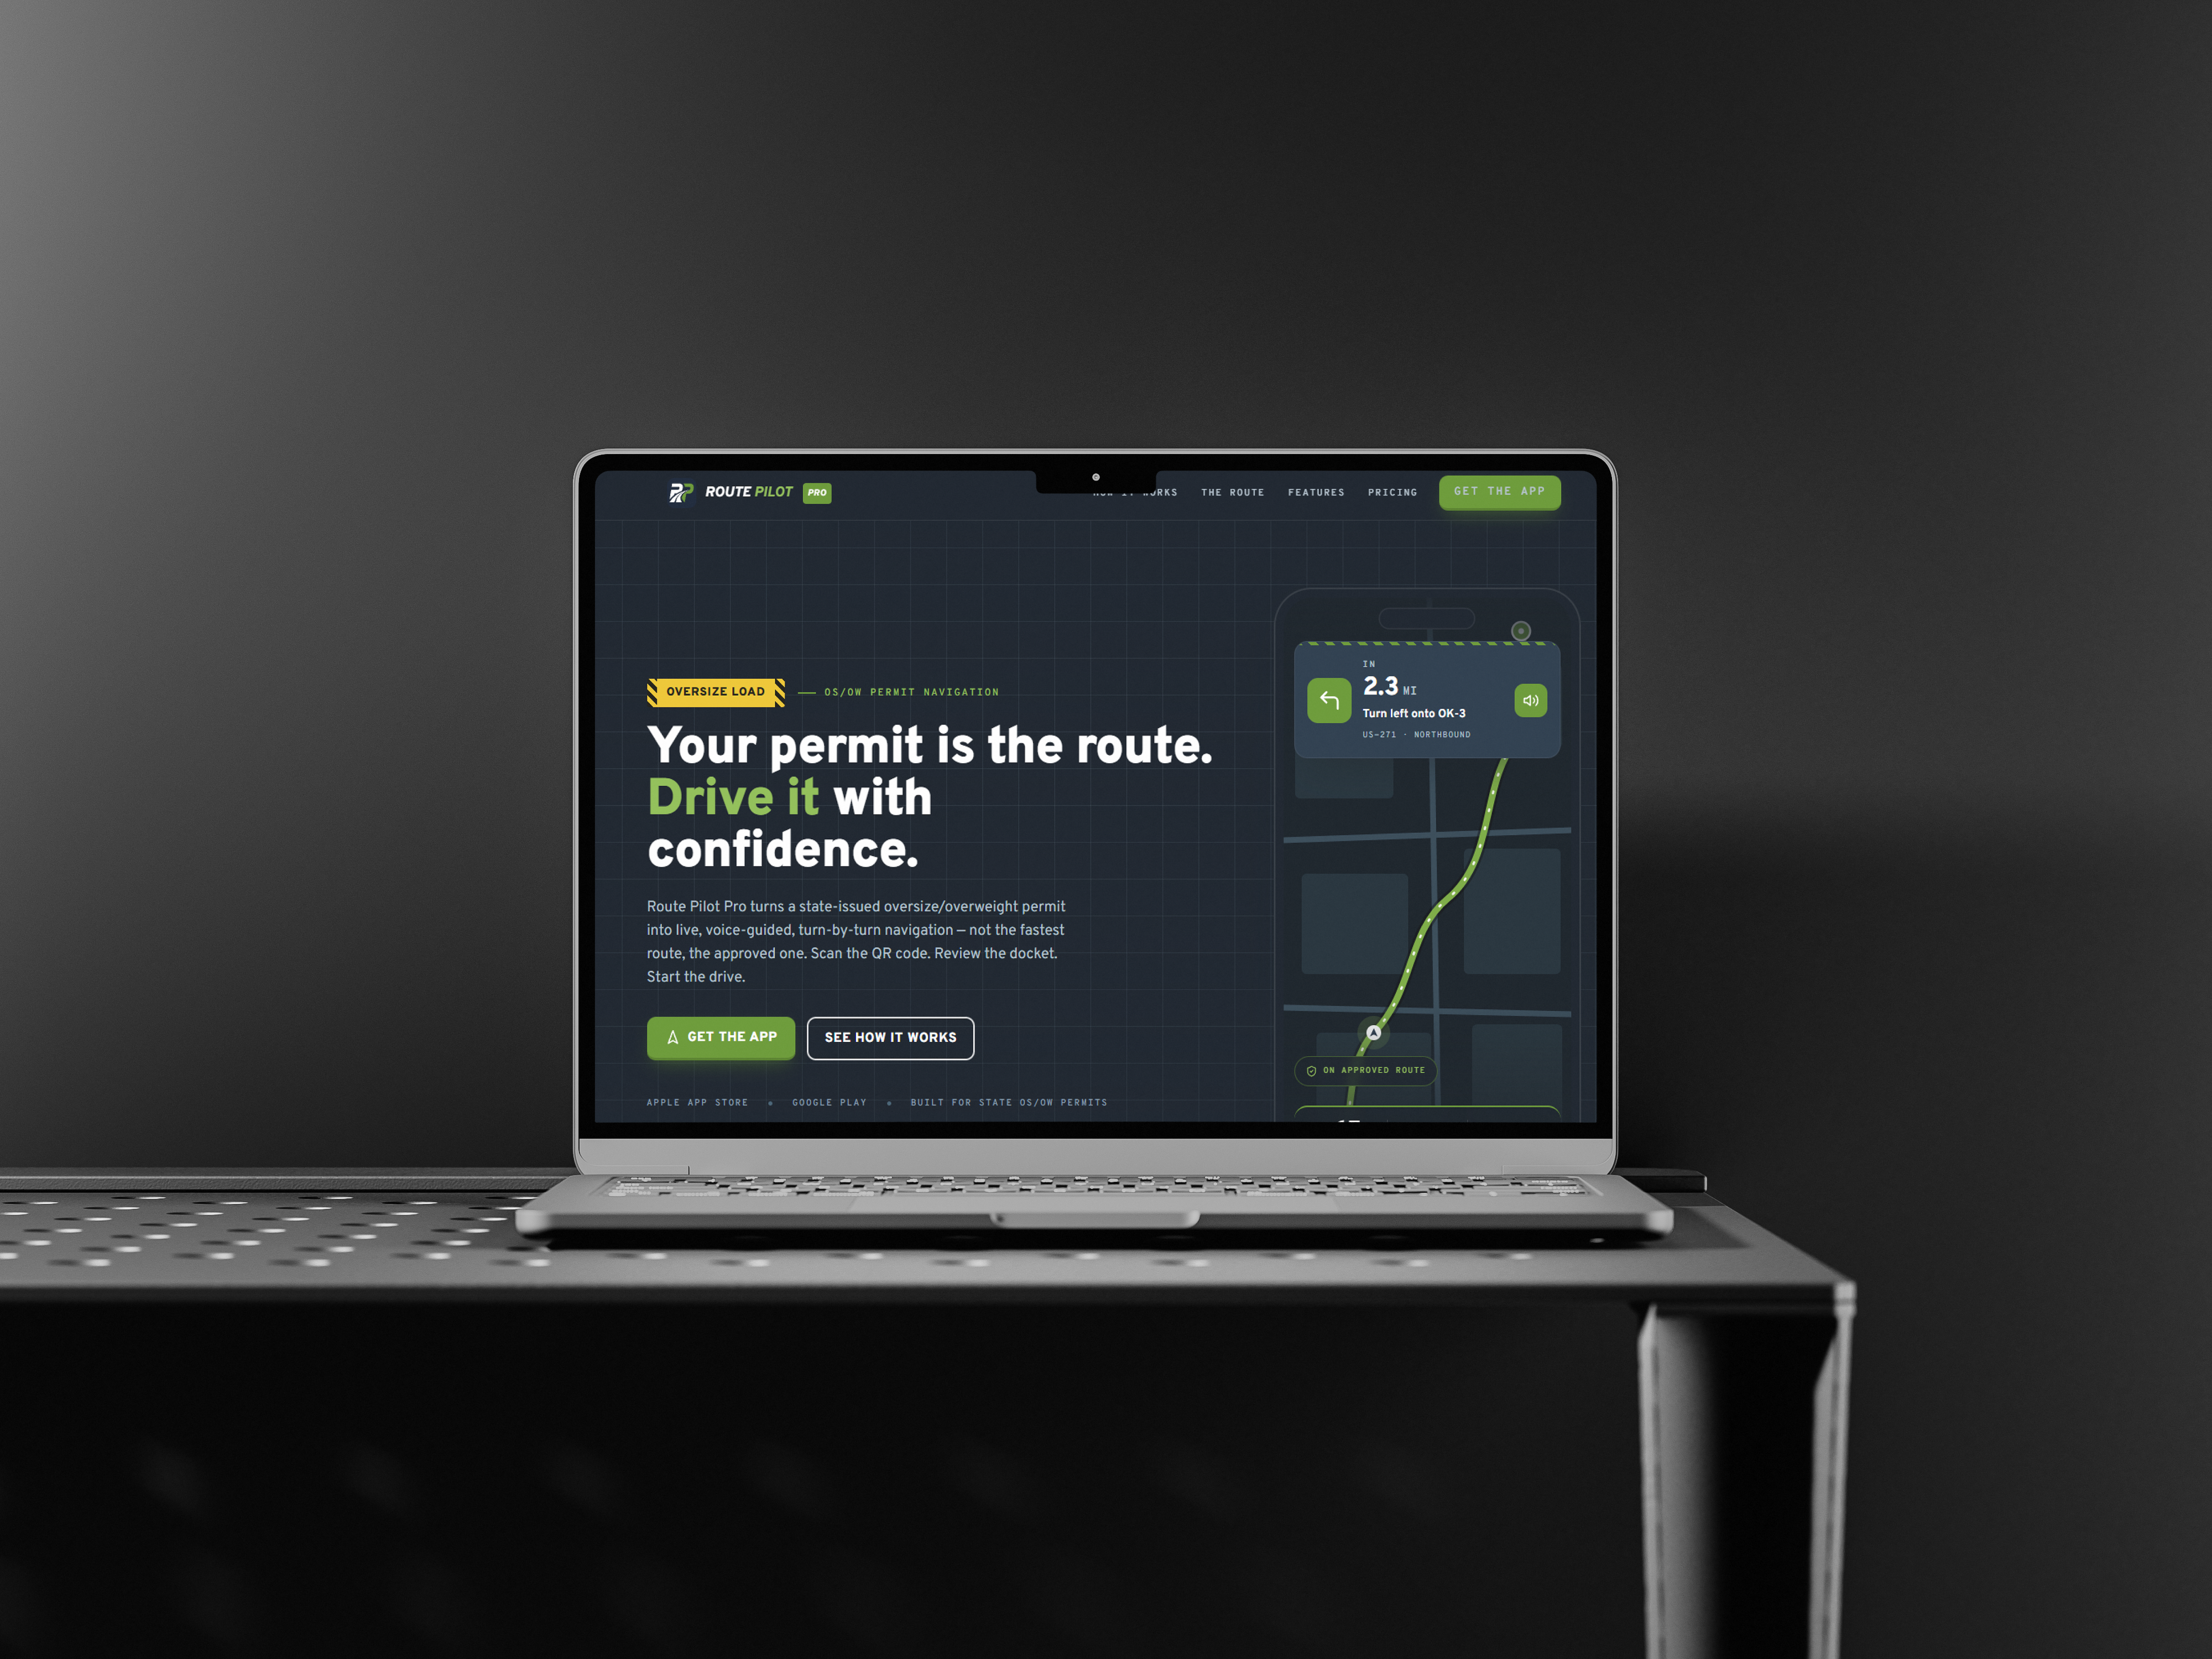
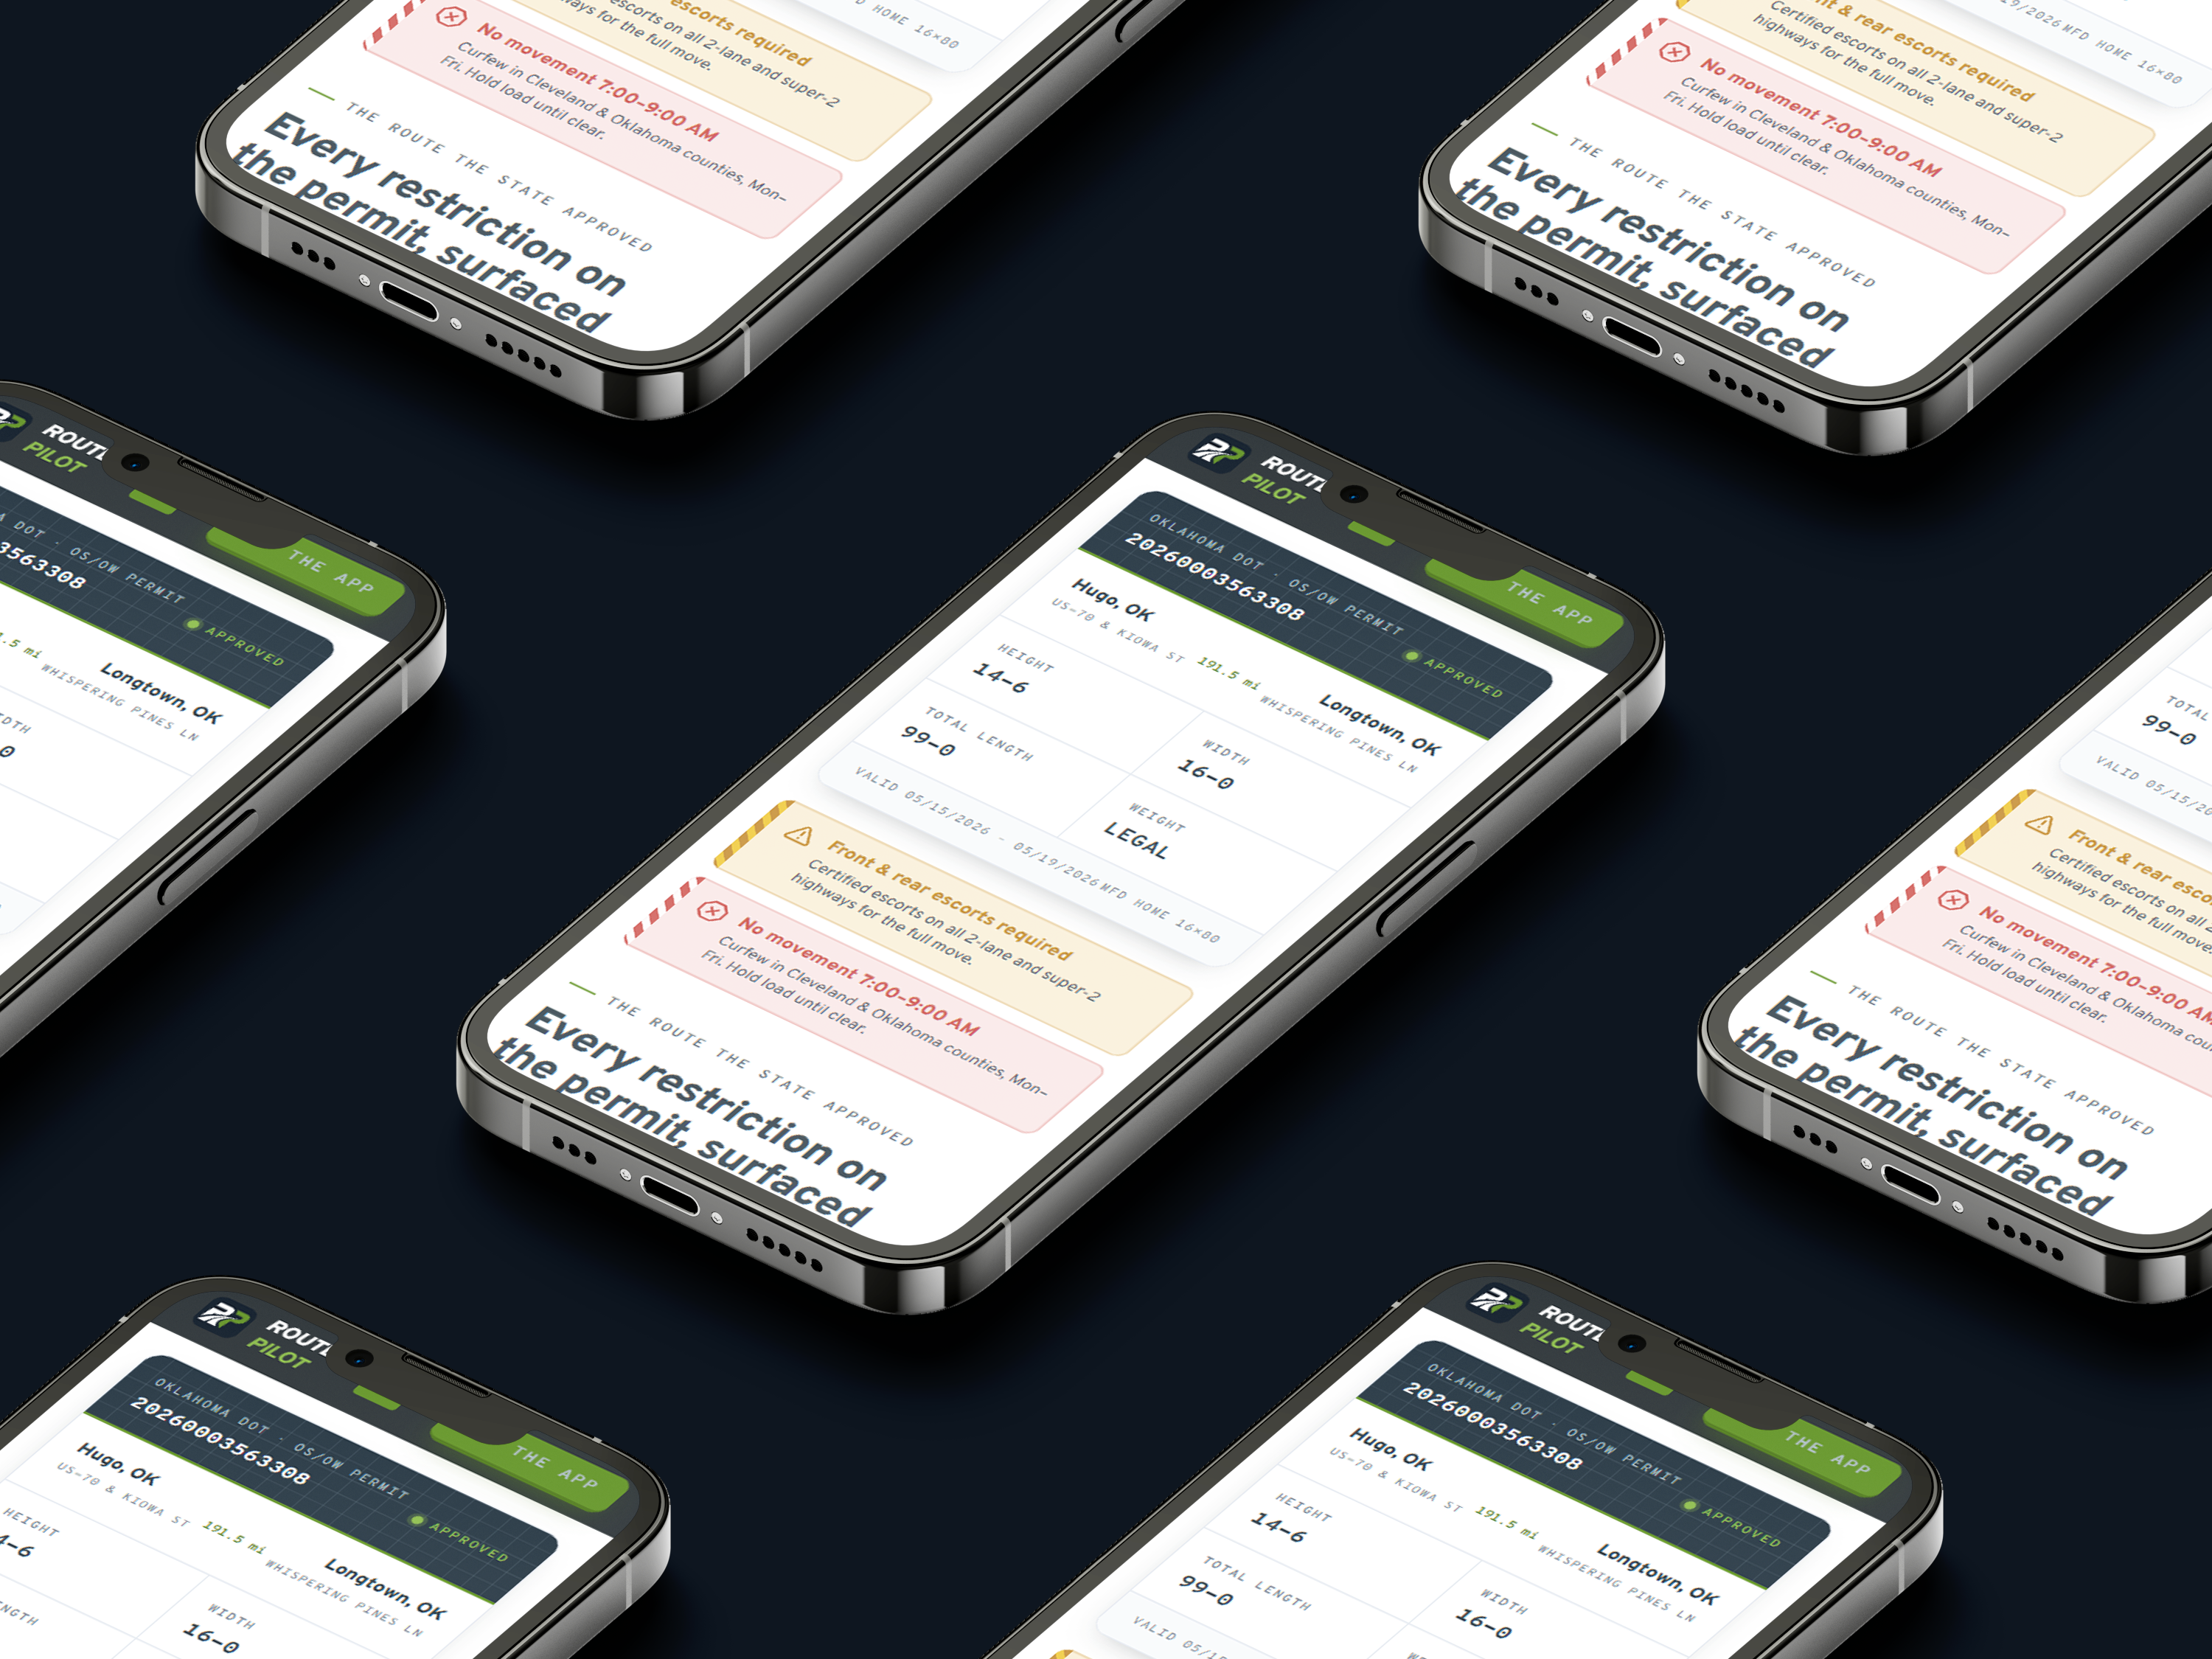
RoutePilot Pro is a mobile navigation app for the US oversize/overweight (OS/OW) commercial trucking industry. A driver scans the QR code on a state-issued permit and the app reconstructs the exact state-mandated, road-following route from the permit PDF, then delivers turn-by-turn navigation on Google Maps with voice guidance. It is built to cover all 50 states, with a subscription model and an internal admin panel for reviewing route quality. Tecaudex delivered end-to-end product development: the Flutter mobile app, a Python/FastAPI backend with a custom route-reconstruction engine, the admin panel, cloud infrastructure, and the App Store and Play Store launch.
Key Features
A closer look at the core features and technologies that shape this project designed for efficiency, innovation, and impact.
- QR Permit Scanning
- Permit PDF Import
- AI Permit Parsing
- Route Reconstruction Engine
- Turn-by-Turn Navigation
- Voice Guidance (TTS)
- Route Quality Verification
- Border-Crossing Handling
- Google & Apple Sign-In
- Subscription & Paywall
- Admin Route Review
- Bad-Route Audit Queue
- English / Spanish
- Account Deletion
- Push Notifications
QR Permit Scanning
Permit PDF Import
AI Permit Parsing
Route Reconstruction Engine
Turn-by-Turn Navigation
Voice Guidance (TTS)
Route Quality Verification
Border-Crossing Handling
Google & Apple Sign-In
Subscription & Paywall
Admin Route Review
Bad-Route Audit Queue
English / Spanish
Account Deletion
Push Notifications
Technology Stack
The tools and services behind the build.


Key Results
Real numbers. Real results. These highlights capture the difference our work made in growth, visibility, and user engagement.
Live
50 states
1,672
Visual Highlights
A visual overview of the finished product highlighting its design.
About the Client
RoutePilot Pro is an in-house Tecaudex product built for the United States oversize/overweight (OS/OW) trucking market. Its users are commercial truck drivers who must follow a specific, state-approved route printed on every OS/OW permit they carry.
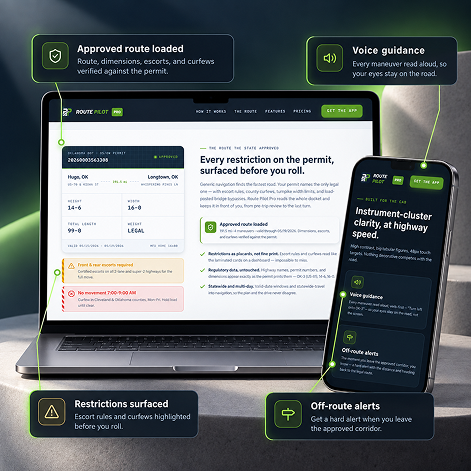
OS/OW drivers typically receive their approved route as hard-to-follow text or a non-navigable PDF. The goal was to turn a scanned permit into reliable turn-by-turn navigation that follows the permitted path exactly and never invents a route it cannot justify.
Challenges
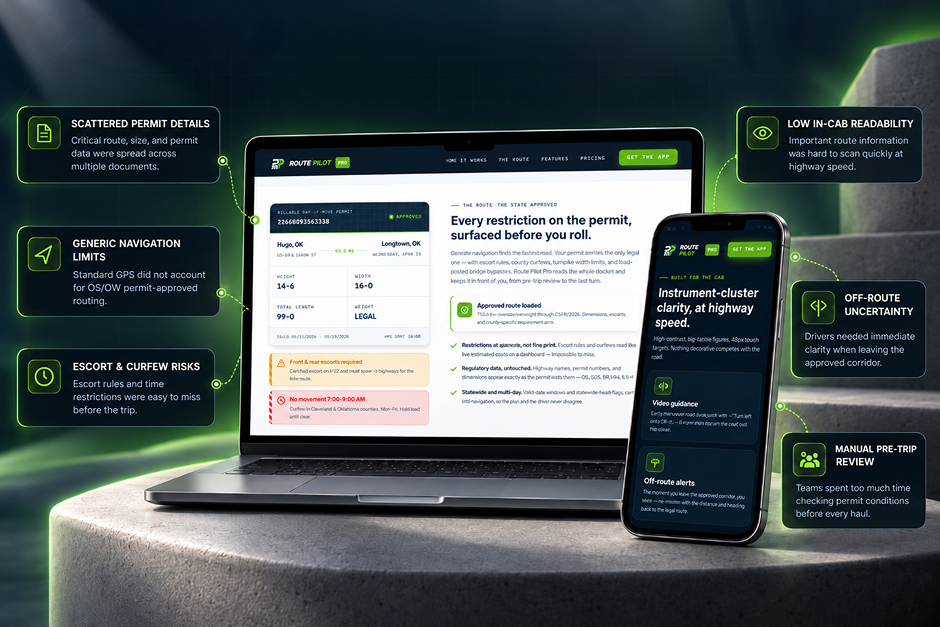
- Permitted routes locked inside PDFs
- No navigable map line in permits
- Hard-to-follow text-only directions
- Every US state formats permits differently
- A wrong turn risks heavy fines
These gaps left oversize-load drivers navigating manually, risking violations, delays, and unsafe detours on restricted roads.
Reconstructing the exact permitted route when the PDF carries no map geometry — solved with constrained path-matching on OpenStreetMap via a self-hosted Valhalla engine, AI-assisted PDF parsing, and verification gates that downgrade or refuse any route the system cannot defend.
Strategy-first planning
Execution with momentum
Similar Projects
No similar projects found.